MuJoCo VR Mocap Example
First, let's import the dependencies.
from asyncio import sleep
from textwrap import dedent

from killport import kill_ports
from vuer import Vuer, VuerSession
from vuer.events import ClientEvent
from vuer.schemas import MuJoCo, Scene, Fog, Sphere, Hands, HandActuator, MotionControllers, MotionControllerActuator
We need to list all of the required files. This needs to be done manually upfront because I don't want to add an additional step of first parsing these assets from the mjcf file.
ASSETS_LIST = (
    dedent("""
    franka_gripper.xml
    assets/finger_0.obj
    assets/finger_1.obj
    assets/hand.stl
    assets/hand_0.obj
    assets/hand_1.obj
    assets/hand_2.obj
    assets/hand_3.obj
    assets/hand_4.obj
    assets/bin.xml
    assets/table.xml
    """)
    .strip()
    .split("\n")
)
Now you can instantiate the vuer server:
kill_ports(ports=[8012])
app = Vuer()
Note
You need to install
ngrokto promote the local vuer server from ws://localhost:8012 to wss://xxxx.ngrok.io, (note the double w[ss] in the protocol), and pass it as a query parameter that looks like this:https://vuer.ai?ws=wss://xxxxx.ngrok.ioYou also need to load from the correct host for components that requires assets. For example, if you want to load an MuJoCo scene, you use the correct url starting with
https.
# this won't work because it does not have SSL.
asset_pref = f"https://docs.vuer.ai/en/latest/_static/mujoco_scenes/gripper_model/"
Now, to get the mujoco updates, we can listen to the ON_MUJOCO_FRAME event.
@app.add_handler("ON_MUJOCO_FRAME")
async def on_mujoco_frame(event: ClientEvent, sess: VuerSession):
    print("ON_MUJOCO_FRAME", event)
You should get events that looks like these:
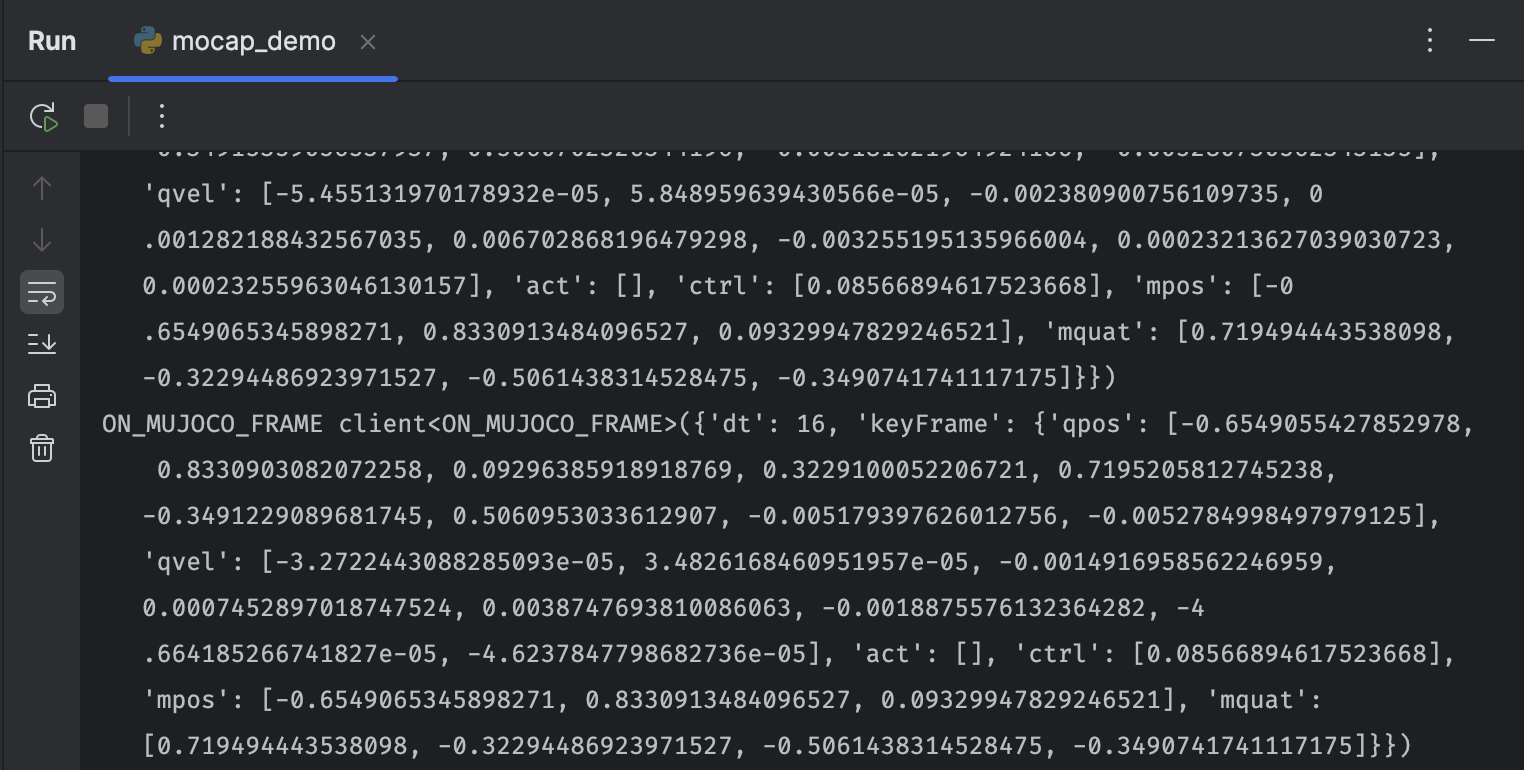
and the main session handler.
@app.spawn(start=True)
async def main(sess: VuerSession):
    # here we setup the staging area. Use Fog to simulate MuJoCo's
    # default style.
    sess.set @ Scene(
        # grid=False,
        bgChildren=[
            Fog(color=0x2C3F57, near=10, far=20),
            # Hands(),
            MotionControllers(),
            Sphere(
                args=[50, 10, 10],
                materialType="basic",
                material=dict(color=0x2C3F57, side=1),
            ),
        ],
    )
    await sleep(0.0005)
    sess.upsert @ MuJoCo(

        # HandActuator(key="pinch-on-squeeze"),
        MotionControllerActuator(high=0.15, low=0.01, ctrlId=-1),
        key="franka-gripper",
        src=asset_pref + "scene.xml",
        assets=[asset_pref + fn for fn in ASSETS_LIST],
        useLights=True,
        timeout=1000000,
        scale=0.1,
    )

    await sleep(100.0)